Selected engineering work · Munich, Germany

Engineering portfolio

Project index

  1. Solar-car driving strategyLarge-scale optimization
  2. Confidence calibration of 3D LiDAR object detectorsMachine-learning research
  3. TUfast autonomous stackAutonomous systems
  4. TUfast matching toolCombinatorial optimization
  5. End-to-end LTE/4G vehicle telemetryEmbedded infrastructure
  6. Self-learning dough-strand controllerIndustrial AI

03 · Autonomous systems

TUfast autonomous stack

Autonomous development, TUfast e.V. · May 2022–May 2024

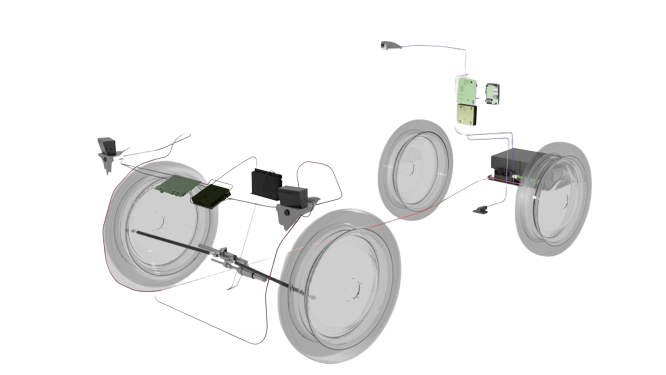
Perception and sensor integration for a Level 4 competition vehicle in the Shell Eco-marathon Autonomous Urban Concept category.

Perception
Built 3D localization, map-less driving, OctoMap mapping, camera/LiDAR fusion, and road and parking-spot detection.
Integration
Developed a custom Sekonix camera driver, merged camera and LiDAR point clouds, used Coral TPU acceleration, and prepared NVIDIA DRIVE.
Leadership
Led the autonomous team from May 2023; trained detectors on a self-developed dataset using LRZ AI Cluster resources.

Technologies

  • ROS2
  • Python
  • C++
  • PyTorch
  • TensorFlow
  • OctoMap
  • Coral TPU

Back to projects

04 · Combinatorial optimization

TUfast matching tool

TUfast engineering software · Public repository

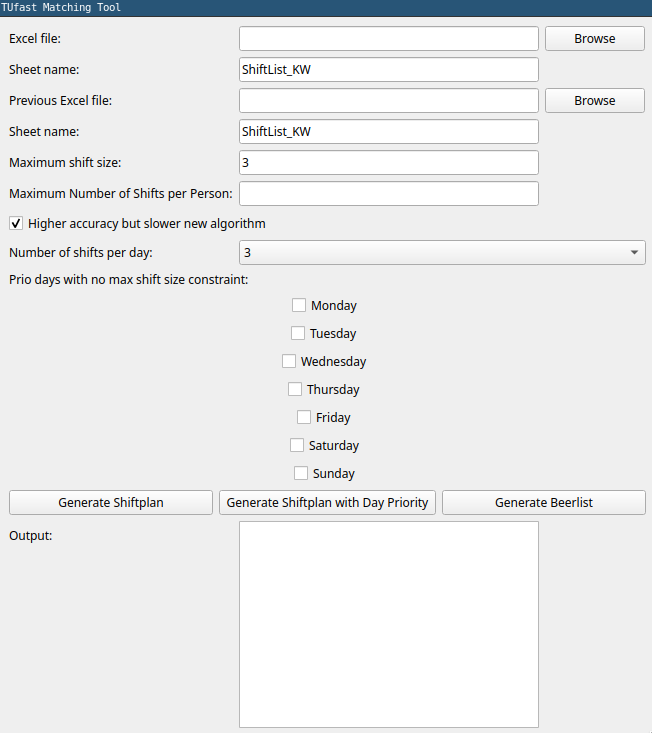
A desktop planning tool that turns constrained shift assignment into a graph-optimization problem.

Problem
Assign shift leads and workers while respecting planning constraints.
Approach
Modeled constraints with maximum-flow and min-cost-flow algorithms using NetworkX and SciPy sparse graphs.
Delivery
Implemented and tested the matching behavior, then packaged it as a PySide6 GUI application.

Technologies

  • Python
  • NetworkX
  • SciPy
  • PySide6
  • Max flow
  • Min-cost flow

Back to projects

05 · Embedded infrastructure

End-to-end LTE/4G vehicle telemetry

TUM School of Computation, Information and Technology · October 2023–May 2024

Reliable, energy-efficient telemetry connecting the muc023+ competition vehicle to remote engineering tools.

Edge
Collected vehicle data with Linux, Raspberry Pi, CAN bus, C/C++, and Python.
Transport
Connected the vehicle over LTE/4G using VPN and Tailscale.
Backend
Used PostgreSQL database replication and a Grafana web interface for remote monitoring.

Technologies

  • Linux
  • Raspberry Pi
  • CAN bus
  • LTE/4G
  • C/C++
  • PostgreSQL
  • Grafana

Back to projects

06 · Industrial AI

Self-learning dough-strand controller

Bachelor’s thesis with Lieken GmbH · June–August 2021

A self-learning controller that keeps bread weight constant as dough consistency changes on an automated production line.

Control
Designed and optimized the controller around two key variables in the automated dough-flow process.
Delivery
Implemented the self-learning controller in Python for an industrial production setting.

Technologies

  • Python
  • PLC
  • ODBC
  • pytest
  • PyPI
  • GitHub Actions

Back to projects